About
The show
Long, honest conversations about the technical and business decisions behind real robots.
I'm Audrow Nash. I'm a robotics engineer, I worked on ROS 2 at Open Robotics, and I've been interviewing the people behind robotics companies and labs since 2014. Guests are founders, CTOs, investors, and researchers across hardware, autonomy, open-source tooling, and robotics financing.
The conversations run long because the useful part is in the details: how a team picked its first customer, why the hardware and software are built the way they are, what the unit economics look like once a robot is deployed, and what's still broken. I do the show to keep learning from people doing the work and to share honest, non-hype coverage of the field.
Guests speak for themselves, and I ask the follow-up questions I'd want answered if I were building or betting on the company. If you build, deploy, or invest in robots, you'll feel at home here.
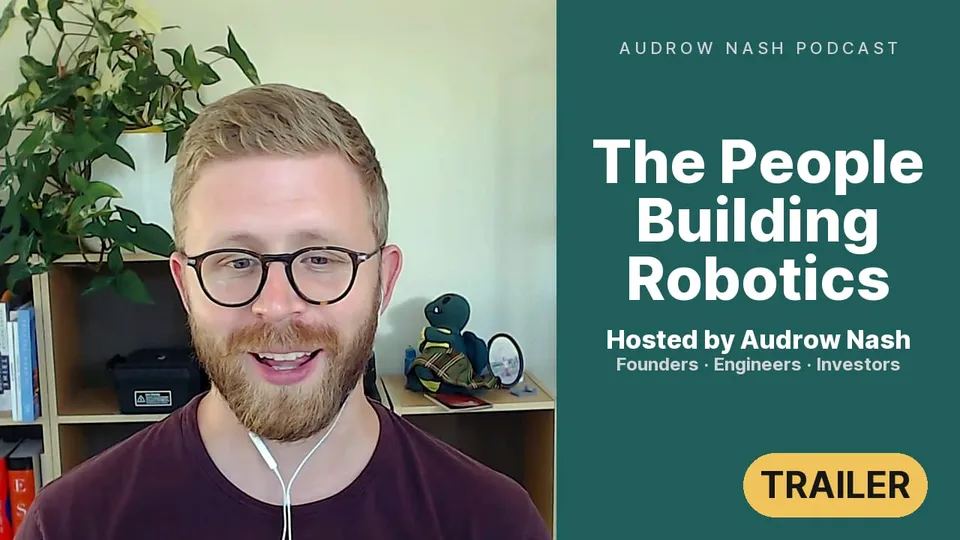
Audrow Nash
I'm a robotics engineer. I did research on quadrotors, computer vision, legged locomotion, and human-robot interaction, then spent several years at Open Robotics on ROS 2, where I was the release lead for ROS 2 Humble.
I've been interviewing roboticists since 2014, first for Robohub, then Sense Think Act, and now here. Across those shows I've sat down with more than a hundred robotics startups, labs, tooling teams, and investors.
Between open-source infrastructure work and a decade of long interviews, I spend a lot of time tracking how the robotics ecosystem fits together: which technical choices hold up in the field, where ROS and developer tooling help or get in the way, and what separates a working business from a good demo.
I live in Lockhart, Texas, a couple of minutes from Proto-Town.
Find me on X, LinkedIn, and YouTube. To get in touch, see the contact page.
Where to listen
Full video episodes are on YouTube. The audio is on Apple Podcasts, Spotify, and any podcast app through the RSS feed.